Technology

From simulation to the final helmet.De la simulación al casco final.

The software grows in four spirals (expression, distributed infrastructure, behaviour and conversation) while the helmet advances in parallel through three prototype phases. A fixed data contract lets the same code run on simulators, on the bust or on the robot.El software crece en cuatro espirales (expresión, infraestructura distribuida, comportamiento y conversación) mientras el casco avanza en paralelo en tres fases de prototipo. Un contrato de datos fijo permite que el mismo código funcione en simuladores, en el busto o en el robot.

Phase 1 · SimulationFase 1 · Simulación
No custom hardwareSin hardware propio
Phase 2 · Bust prototypeFase 2 · Prototipo en busto
Real displays and cameraPantallas y cámara reales
Phase 3 · Final prototypeFase 3 · Prototipo final
Final electronics on the G1Electrónica final sobre el G1
↑ Scroll up for earlier stagesSube para ver etapas anteriores↓ Scroll down for what comes nextBaja para ver las próximas
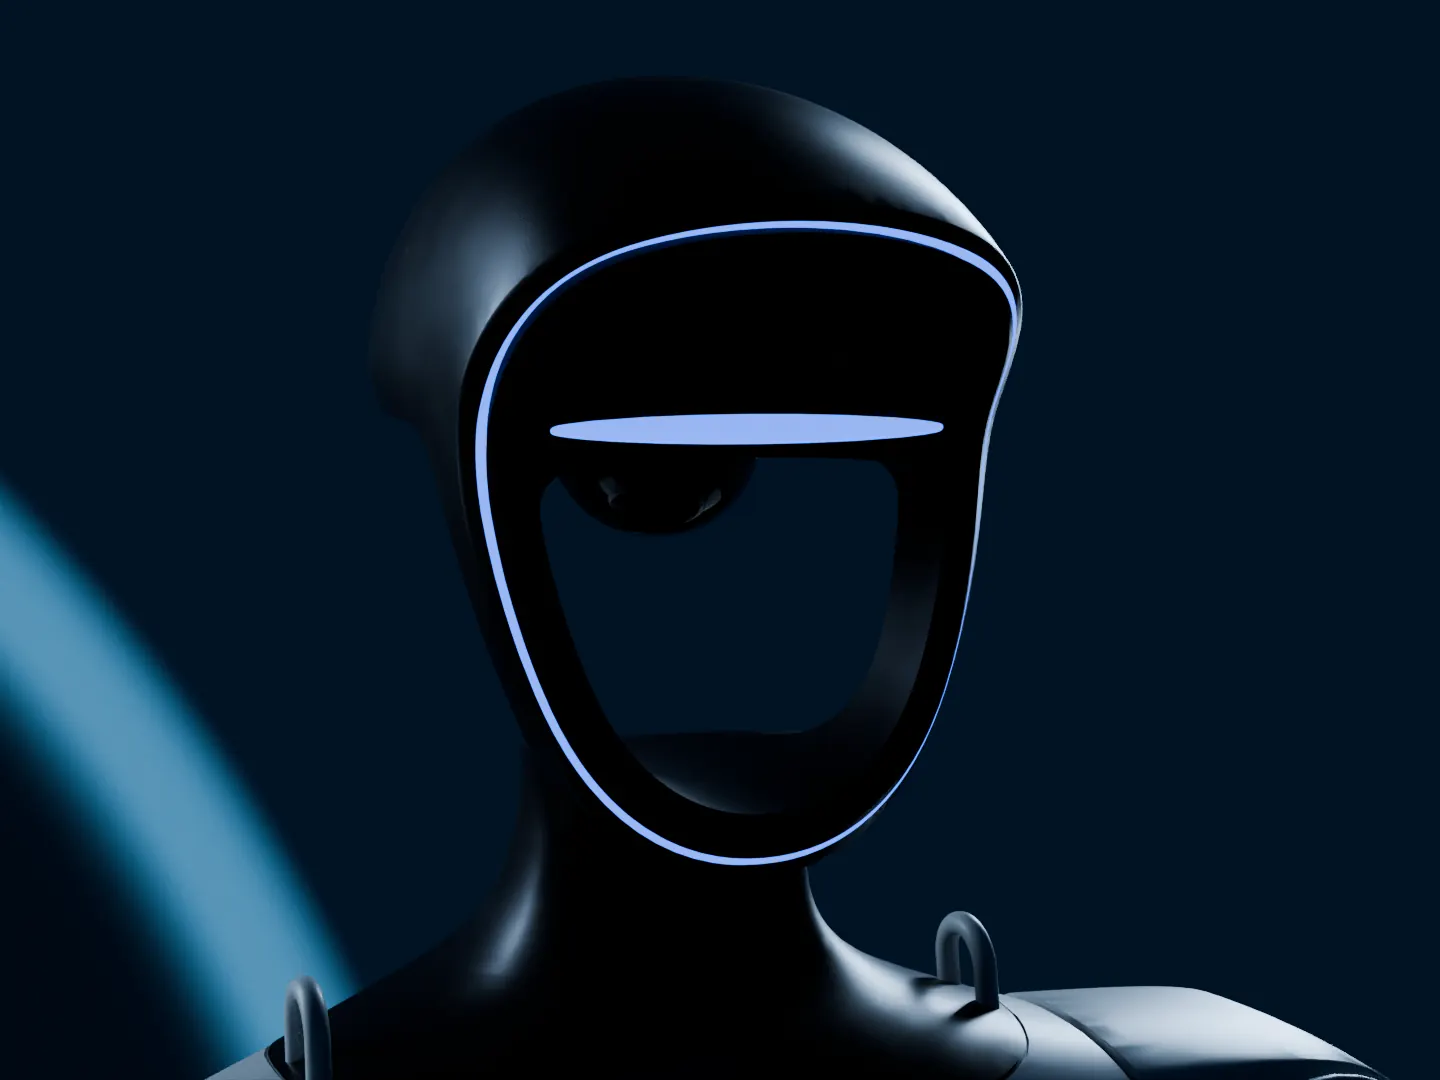
Unitree G1 head with its LED face
Aug 2026 · 03–14Phase 1Fase 1DoneHecho

The starting pointEl punto de partida

Humanoids like the Unitree G1 are physically capable, but their face is a strip of LEDs. The project starts by studying how people read gaze and what the market already offers.Humanoides como el Unitree G1 son físicamente capaces, pero su cara es una tira de LED. El proyecto empieza estudiando cómo leen las personas la mirada y qué ofrece ya el mercado.

  • State of the art and market studyEstado de la cuestión y del mercado
  • LVGL, the display toolchain and ROS 2, explored from the first expression prototypeLVGL, el entorno de las pantallas y ROS 2, a partir del primer prototipo de expresiones
Silhouette of the helmet design
Aug 2026 · 17–28Phase 1 → 2Fase 1 → 2DoneHecho

Requirements, contract and helmet designRequisitos, contrato y diseño del casco

The system is modelled before it is built. The eye state gets a fixed contract, and the helmet is designed over the geometry of the G1 head so it adds to the robot without blocking its sensors.El sistema se modela antes de construirlo. El estado de los ojos recibe un contrato fijo, y el casco se diseña sobre la geometría de la cabeza del G1 para sumar sin tapar sus sensores.

  • Requirements and SysML modelRequisitos y modelo SysML
  • Eye-state contract and patch schemaContrato del estado de los ojos y esquema de parches
  • Helmet designed on the G1 head modelCasco diseñado sobre el modelo de la cabeza del G1
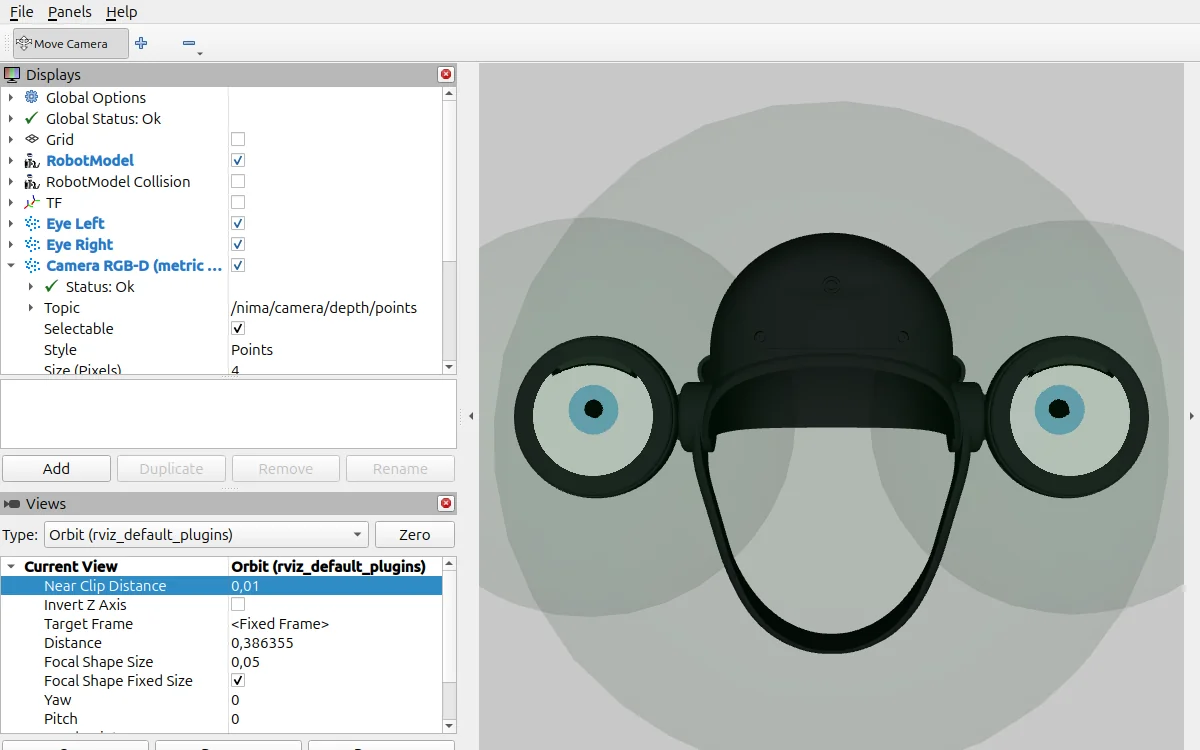
The helmet and both eyes in RViz, with the ROS 2 displays panel
Aug 31 – Sep 11Phase 1Fase 1DoneHecho

Parametric eyes, in simulationOjos paramétricos, en simulación

Without any custom hardware yet, the eyes live in desktop simulators and in RViz, and a webcam stands in for the helmet camera.Todavía sin hardware propio, los ojos viven en simuladores de escritorio y en RViz, y una cámara web sustituye a la del casco.

  • Parametric renderer with independent curvature per eyelidRenderizador paramétrico con curvatura independiente por párpado
  • Geometric model of the head for RVizModelo geométrico de la cabeza para RViz
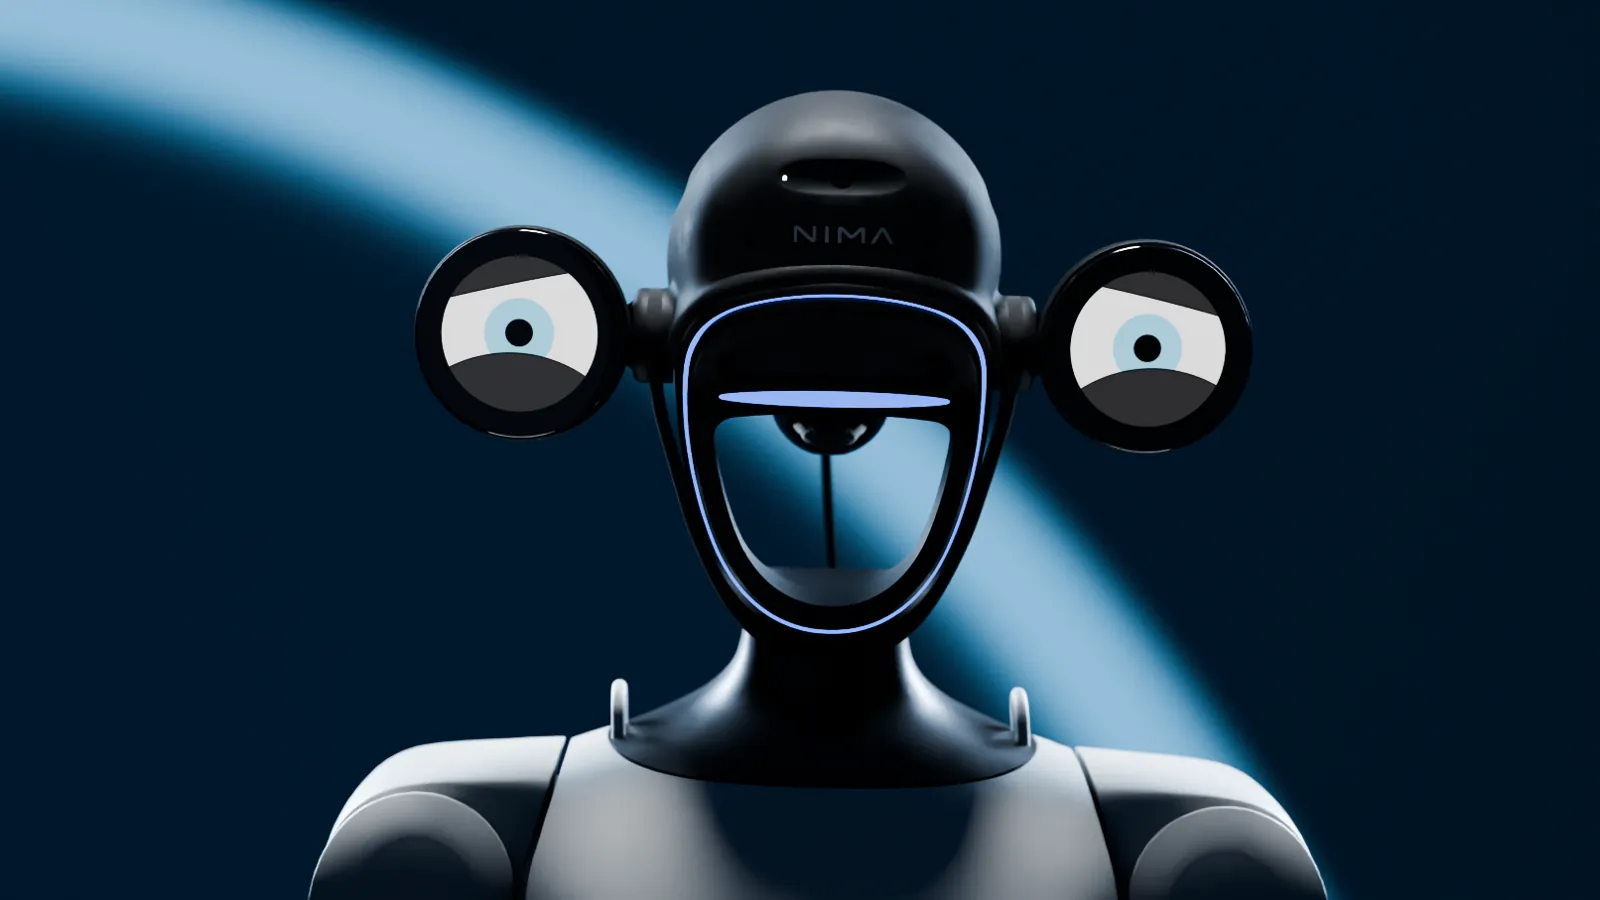
Render of the helmet with both eye displays on the bust The real helmet with both eye displays on the bust
Sep 2026 · 14–25Phase 2Fase 2MilestoneHito

Real displays on the bustPantallas reales en el busto

The helmet goes physical on a 3D-printed replica of the G1 head with a flat base, so firmware, network and perception can be tested away from the robot.El casco pasa a ser físico sobre una réplica impresa en 3D de la cabeza del G1 con la base plana, para probar firmware, red y percepción fuera del robot.

  • Display firmware with direct rasterisationFirmware de las pantallas con rasterizado directo
  • Right-angle mounting of the round displaysMontaje en ángulo recto de las pantallas circulares
  • Bust operationalBusto operativo
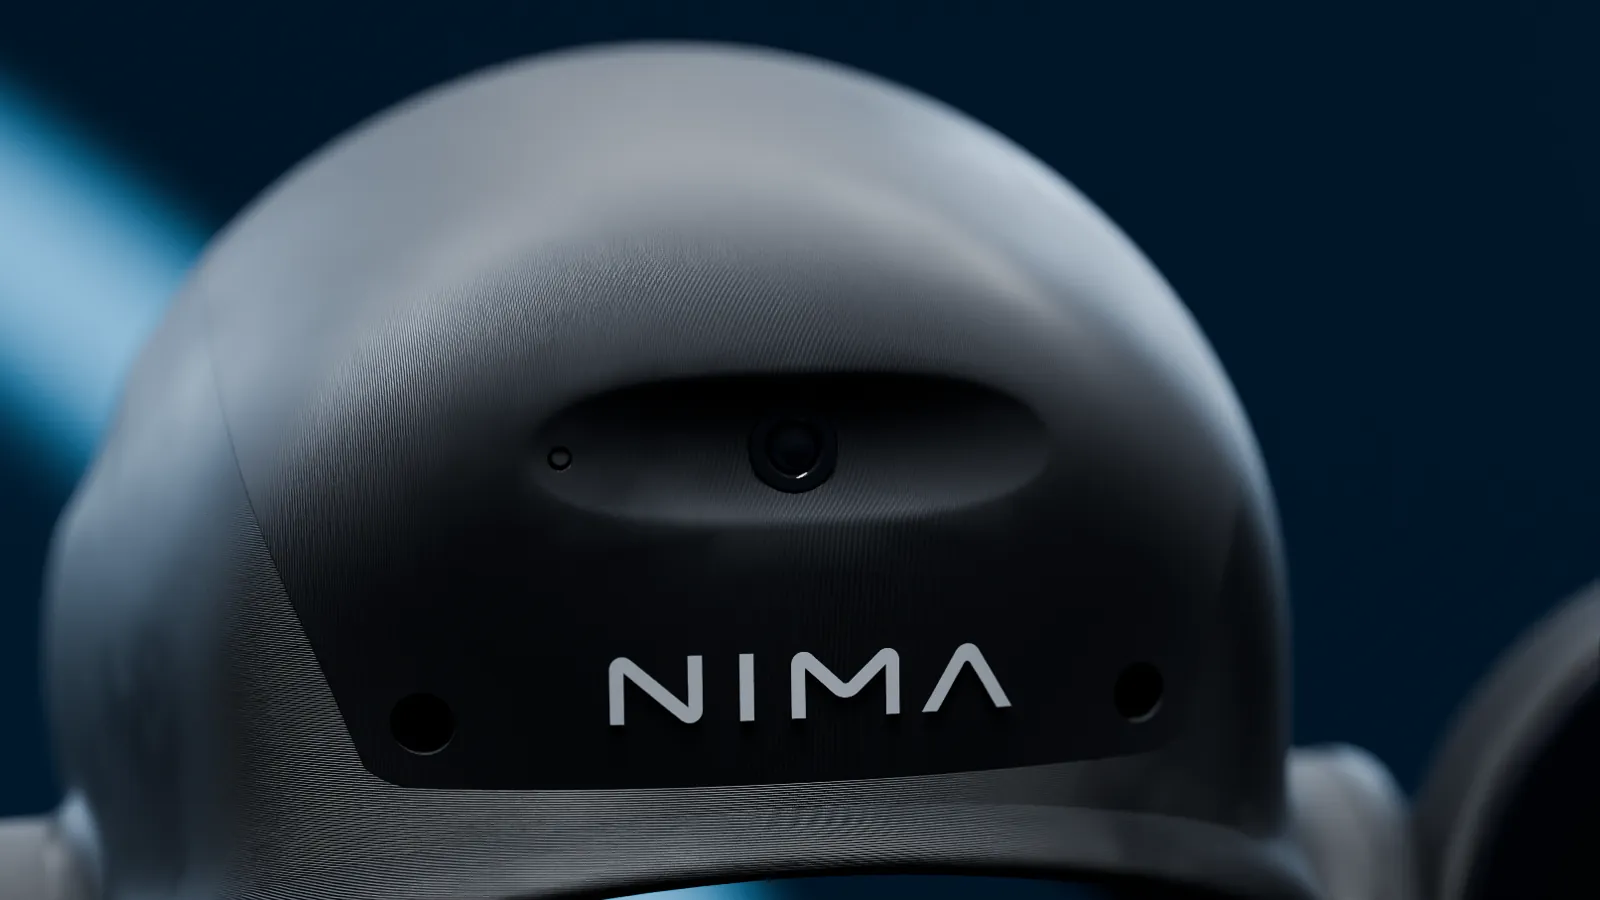
Wide-angle camera at the front of the helmet
Sep 28 – Oct 9Phase 2Fase 2DoneHecho

A distributed headUna cabeza distribuida

The displays and the camera join the ROS 2 graph without running ROS themselves. Moving the head to a new place no longer means configuring every device by hand.Las pantallas y la cámara se integran en el grafo de ROS 2 sin ejecutar ROS. Llevar la cabeza a otro sitio ya no obliga a configurar cada dispositivo a mano.

  • Single fusion point for the eye statePunto único de fusión del estado de los ojos
  • Wi-Fi with Bluetooth provisioning and passive discoveryWi-Fi con provisión por Bluetooth y descubrimiento pasivo
  • Camera video stream and signed updatesVídeo de la cámara y actualizaciones firmadas
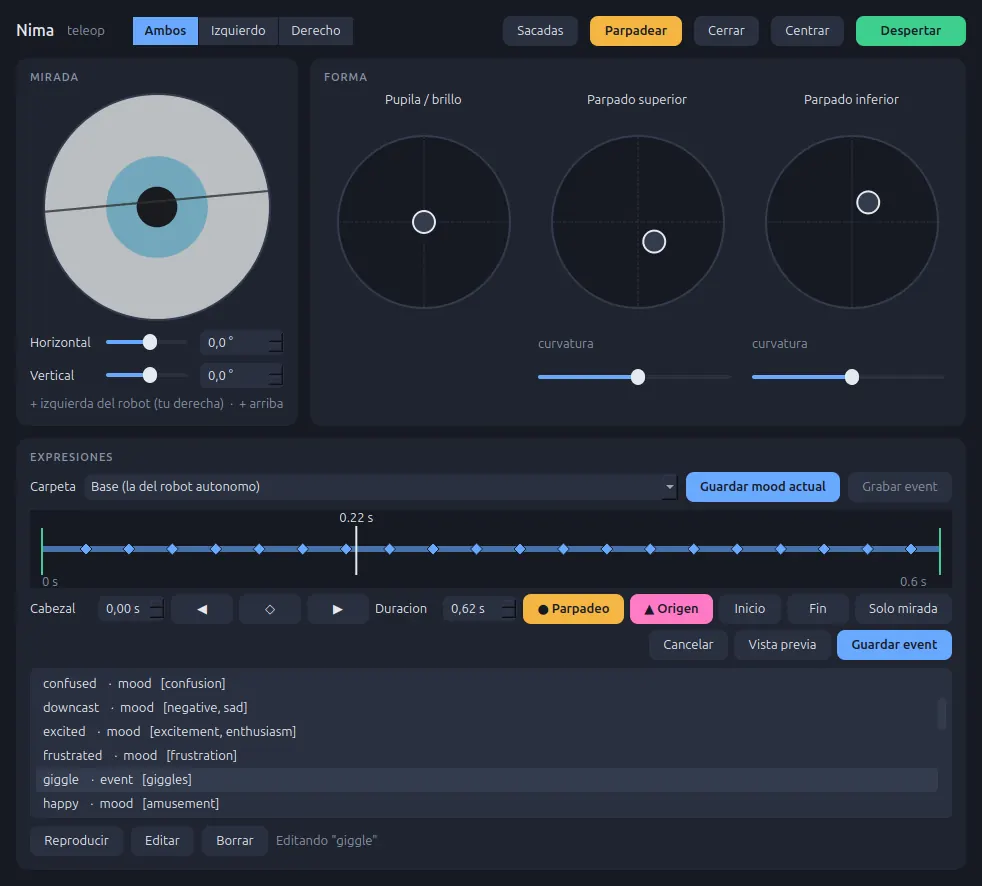
Expression and event editor
Oct 2026 · 13–30Phase 2Fase 2DoneHecho

Perception, attention and expressionPercepción, atención y expresión

The head starts to behave: it detects people, decides whom to look at and expresses itself with its own repertoire.La cabeza empieza a comportarse: detecta personas, decide a quién mirar y se expresa con un repertorio propio.

  • Social perception and episode-based attentionPercepción social y atención por episodios
  • Expression node with 23 expressions and its editorNodo de expresión con 23 expresiones y su editor
  • Both eyes updated in sync at 50 HzEnvío sincronizado a ambos ojos a 50 Hz
HAT One speaking on the G1
Oct 2026Phase 2Fase 2DoneHecho

ConversationConversación

Spoken conversation coordinated with expression, so the robot reacts quickly and its gaze and gestures stay in step with its voice. It can follow a script, or run in autonomous mode and hold conversations on its own.Conversación hablada coordinada con la expresión, para que el robot reaccione rápido y su mirada y sus gestos vayan al ritmo de su voz. Puede seguir un guion o funcionar en modo autónomo y mantener conversaciones por sí solo.

  • Short pre-recorded reactions to cut the waiting timeReacciones breves pregrabadas para reducir la espera
  • Gestures timed to the audio clockGestos según el reloj del audio
  • Autonomous mode for open conversationsModo autónomo para mantener conversaciones
  • Dictated voiceVoz dictada
WE ARE HEREESTAMOS AQUÍ
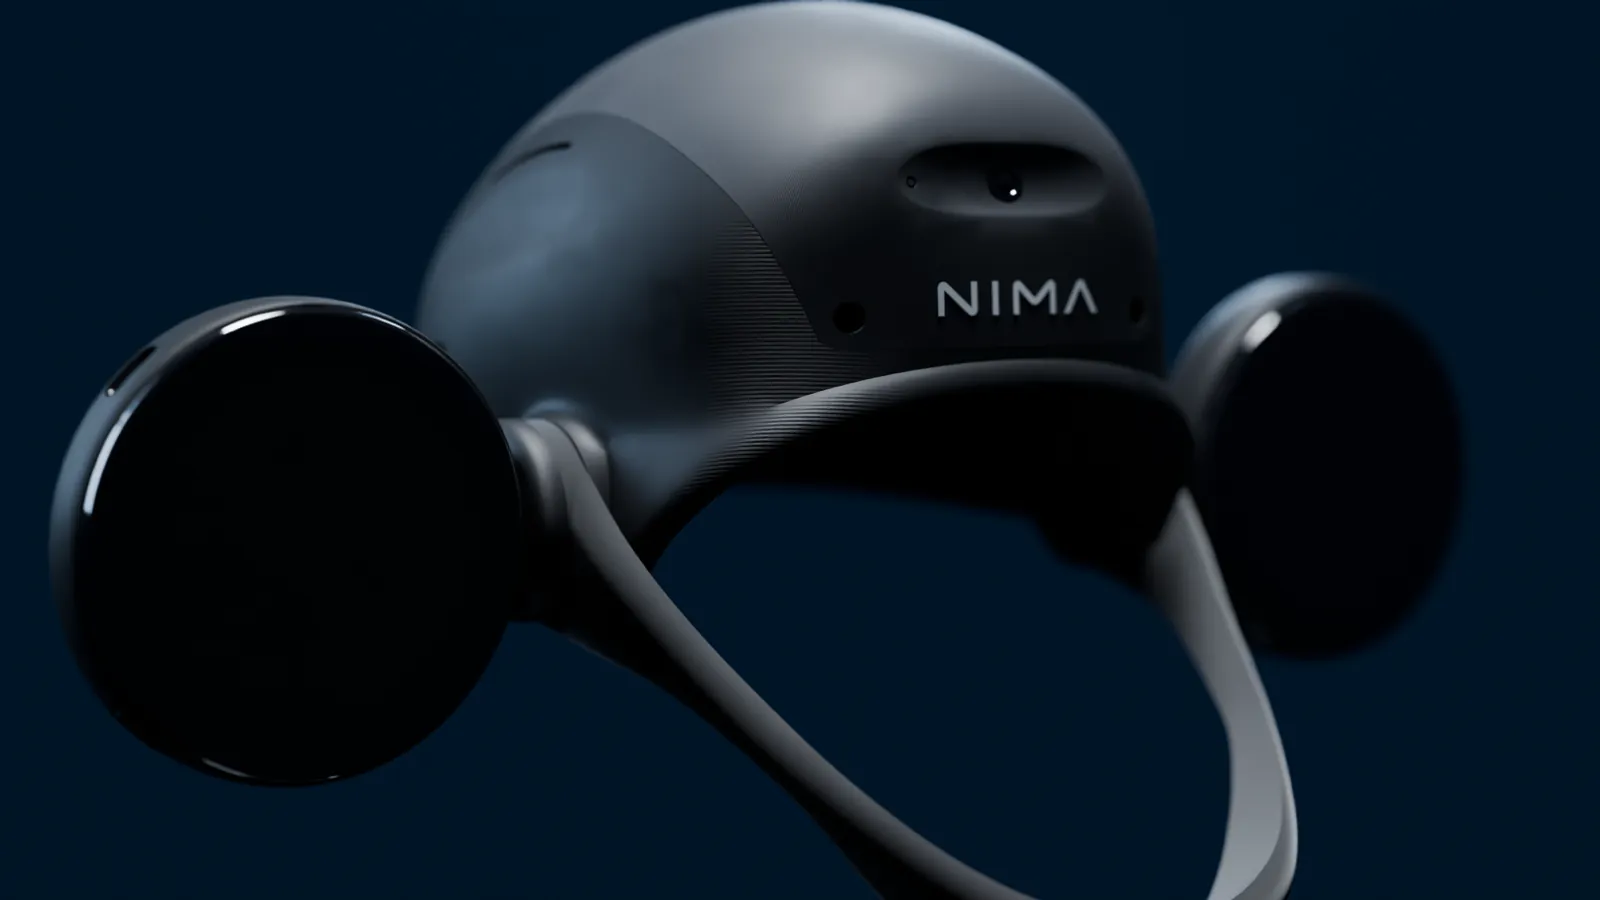
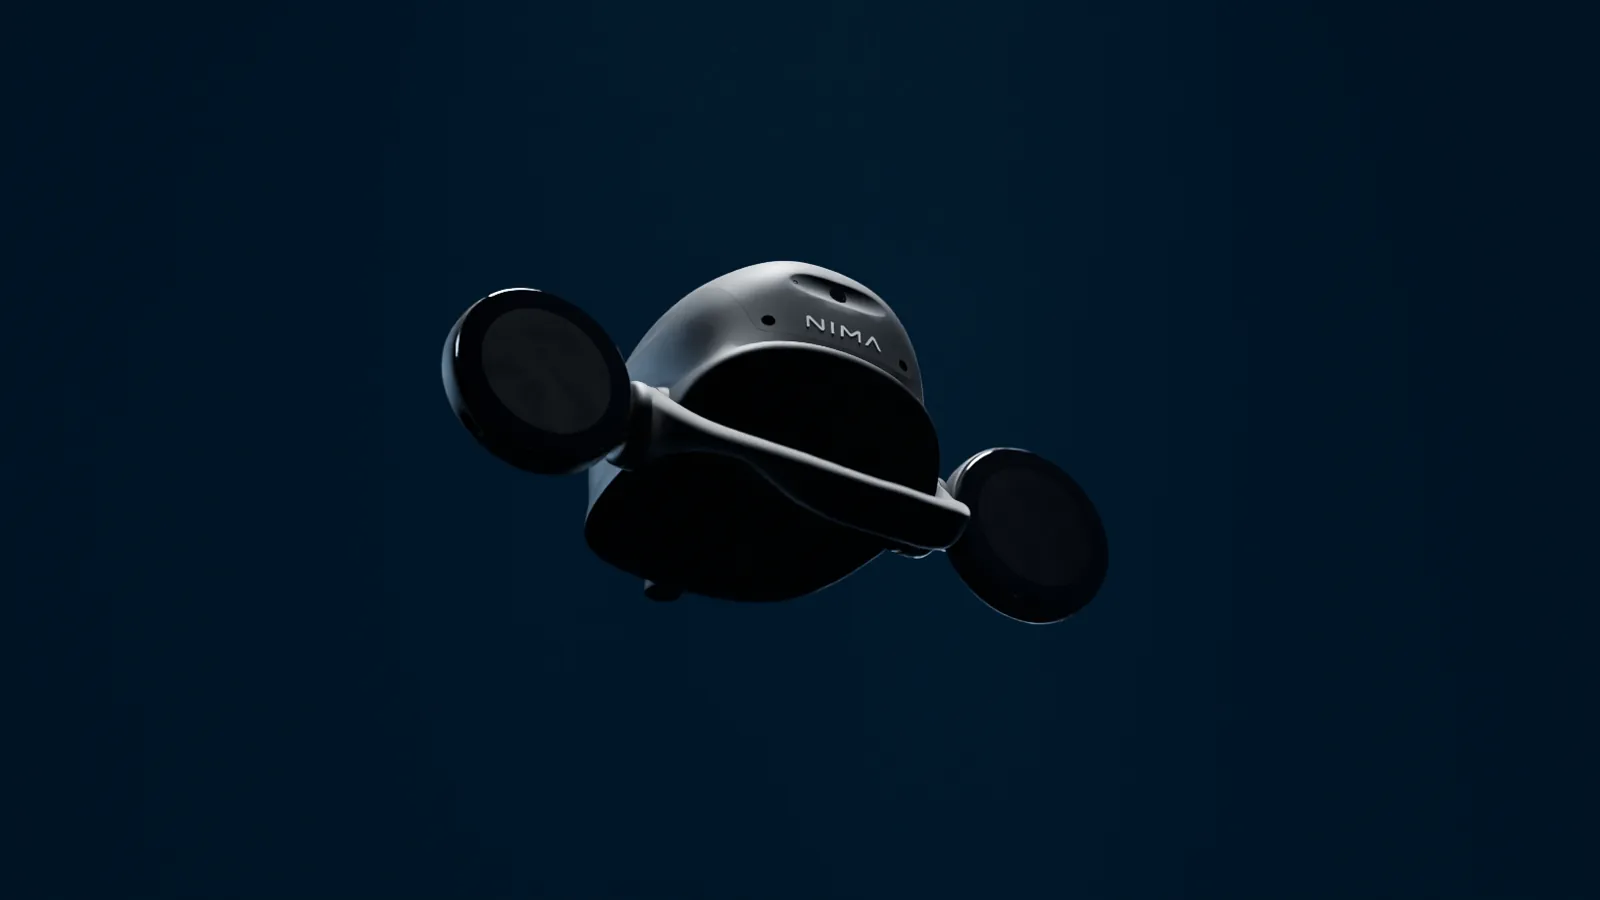
Final helmet design, three-quarter view
Oct – Nov 2026Phase 3Fase 3In progressEn curso

Designing and fabricating the final helmetDiseño y fabricación del casco final

The bust phase is closing. The final prototype brings the definitive electronics, so the helmet works on the bust or mounted on the G1 with a single cable.La fase de busto se está cerrando. El prototipo final trae la electrónica definitiva, para que el casco funcione en el busto o montado en el G1 con un único cable.

  • One converter powers the three devices from a single connector at the napeUn conversor alimenta los tres dispositivos desde un único conector en la nuca
  • Powered from the robot itself, without modifying itAlimentado desde el propio robot, sin modificarlo
  • An LED that shows when the camera is activeUn LED que indica cuándo la cámara está activa
  • Final cabling and the printed shellCableado final y carcasa impresa
NextPróximamente
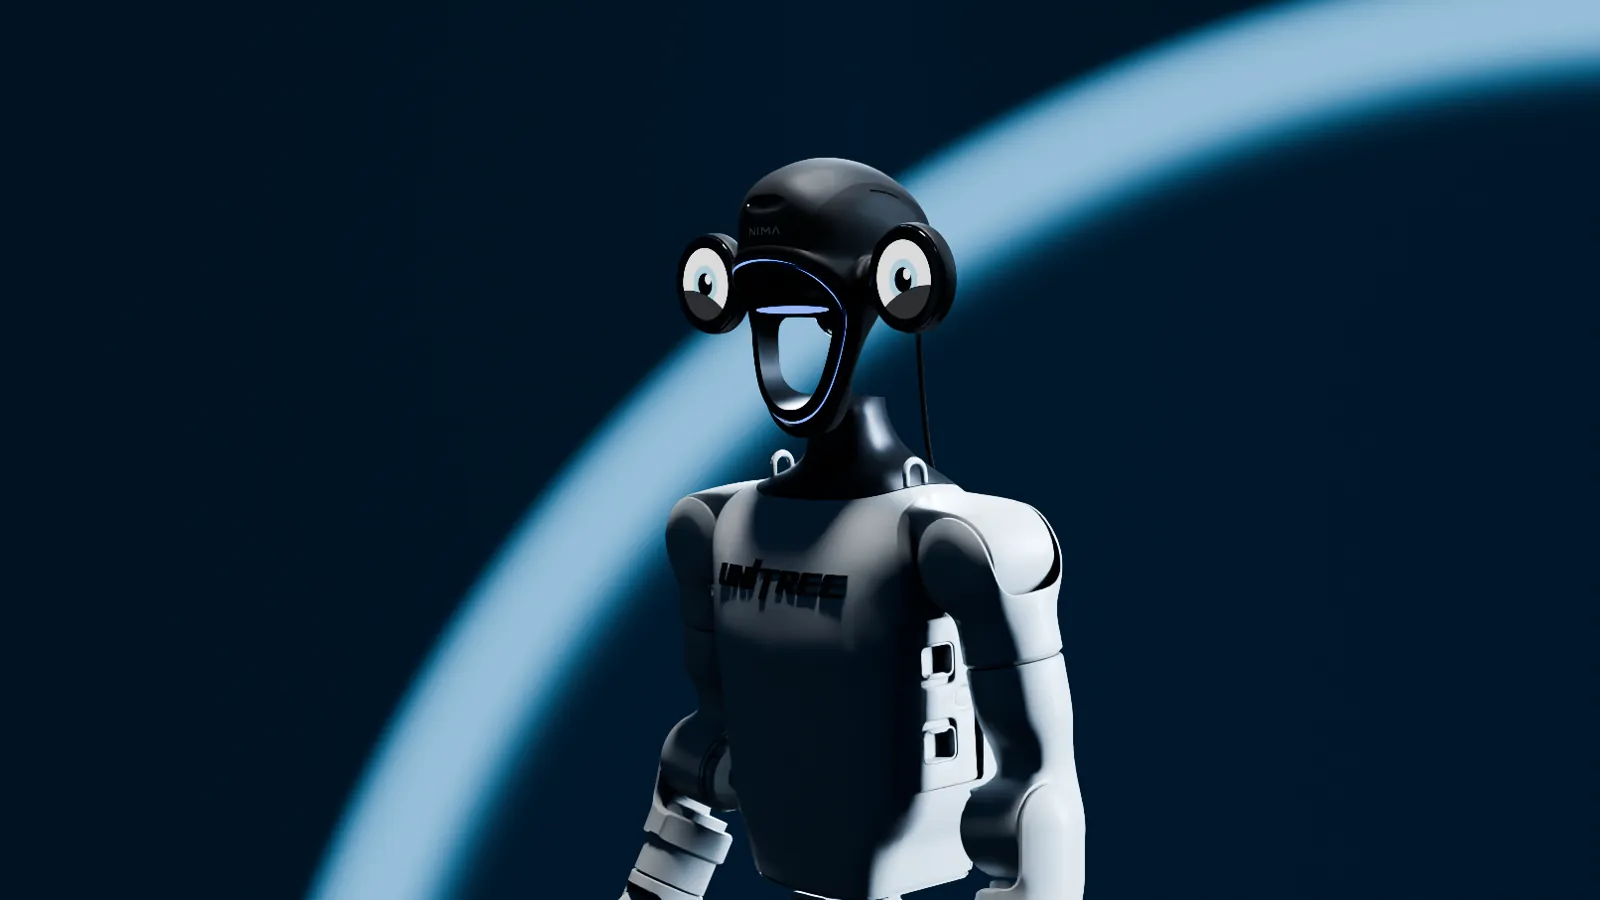
HAT One mounted on the Unitree G1, front three-quarter view
Nov 16 – Dec 4Phase 3Fase 3NextSiguiente

On the robotSobre el robot

The final helmet is mounted on the G1 and the platform is measured end to end: in simulation, on the bust and on the robot.El casco final se monta en el G1 y la plataforma se mide de principio a fin: en simulación, sobre el busto y sobre el robot.

  • Display latency, sync between the eyes and frame rateLatencia de las pantallas, sincronía entre ojos y fotogramas por segundo
  • From perception to gaze, and from end of turn to first audioDe la percepción a la mirada, y del fin de turno al primer audio
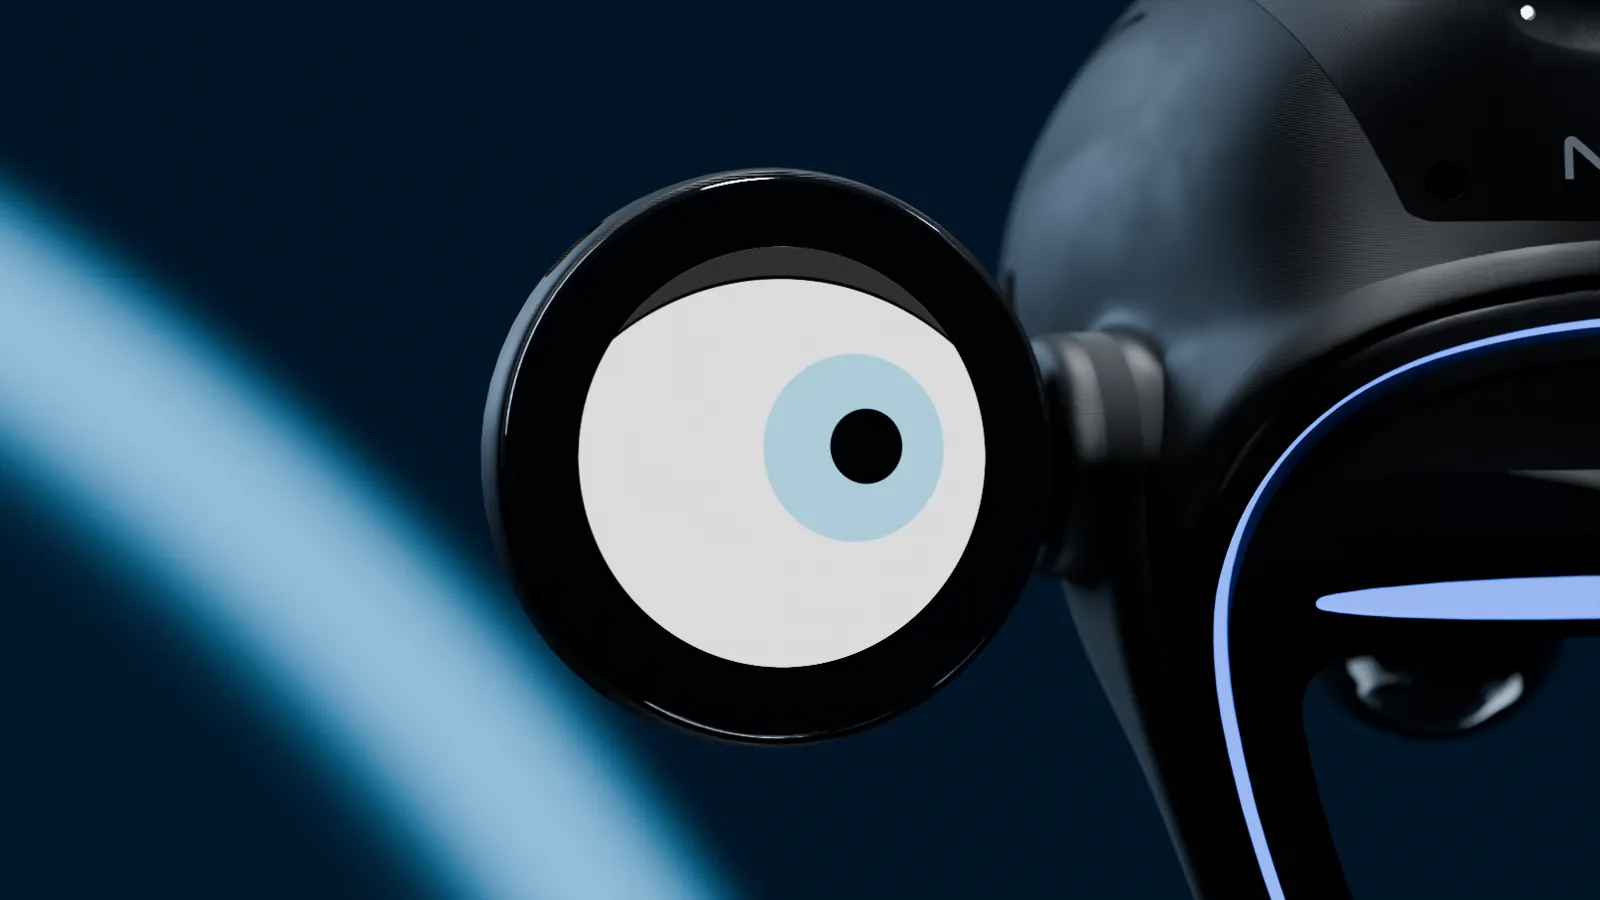
Close-up of an expressive eye display
2027LaterMás adelante

Open studies and releaseEstudios abiertos y publicación

With the platform validated, the next step is people: running the open studies on gaze, trust and deception, and publishing documentation and material.Con la plataforma validada, el siguiente paso son las personas: llevar a cabo los estudios abiertos sobre mirada, confianza y engaño, y publicar la documentación y el material.